Yellowfin hind · w40_fish3
Cephalopholis hemistiktos · Serranidae · 74% · medium reconstructed model: fair
Reviewer: very dark model; outline right
Where it comes from
3D and 4D model
loading 3D gaussians…
Poster
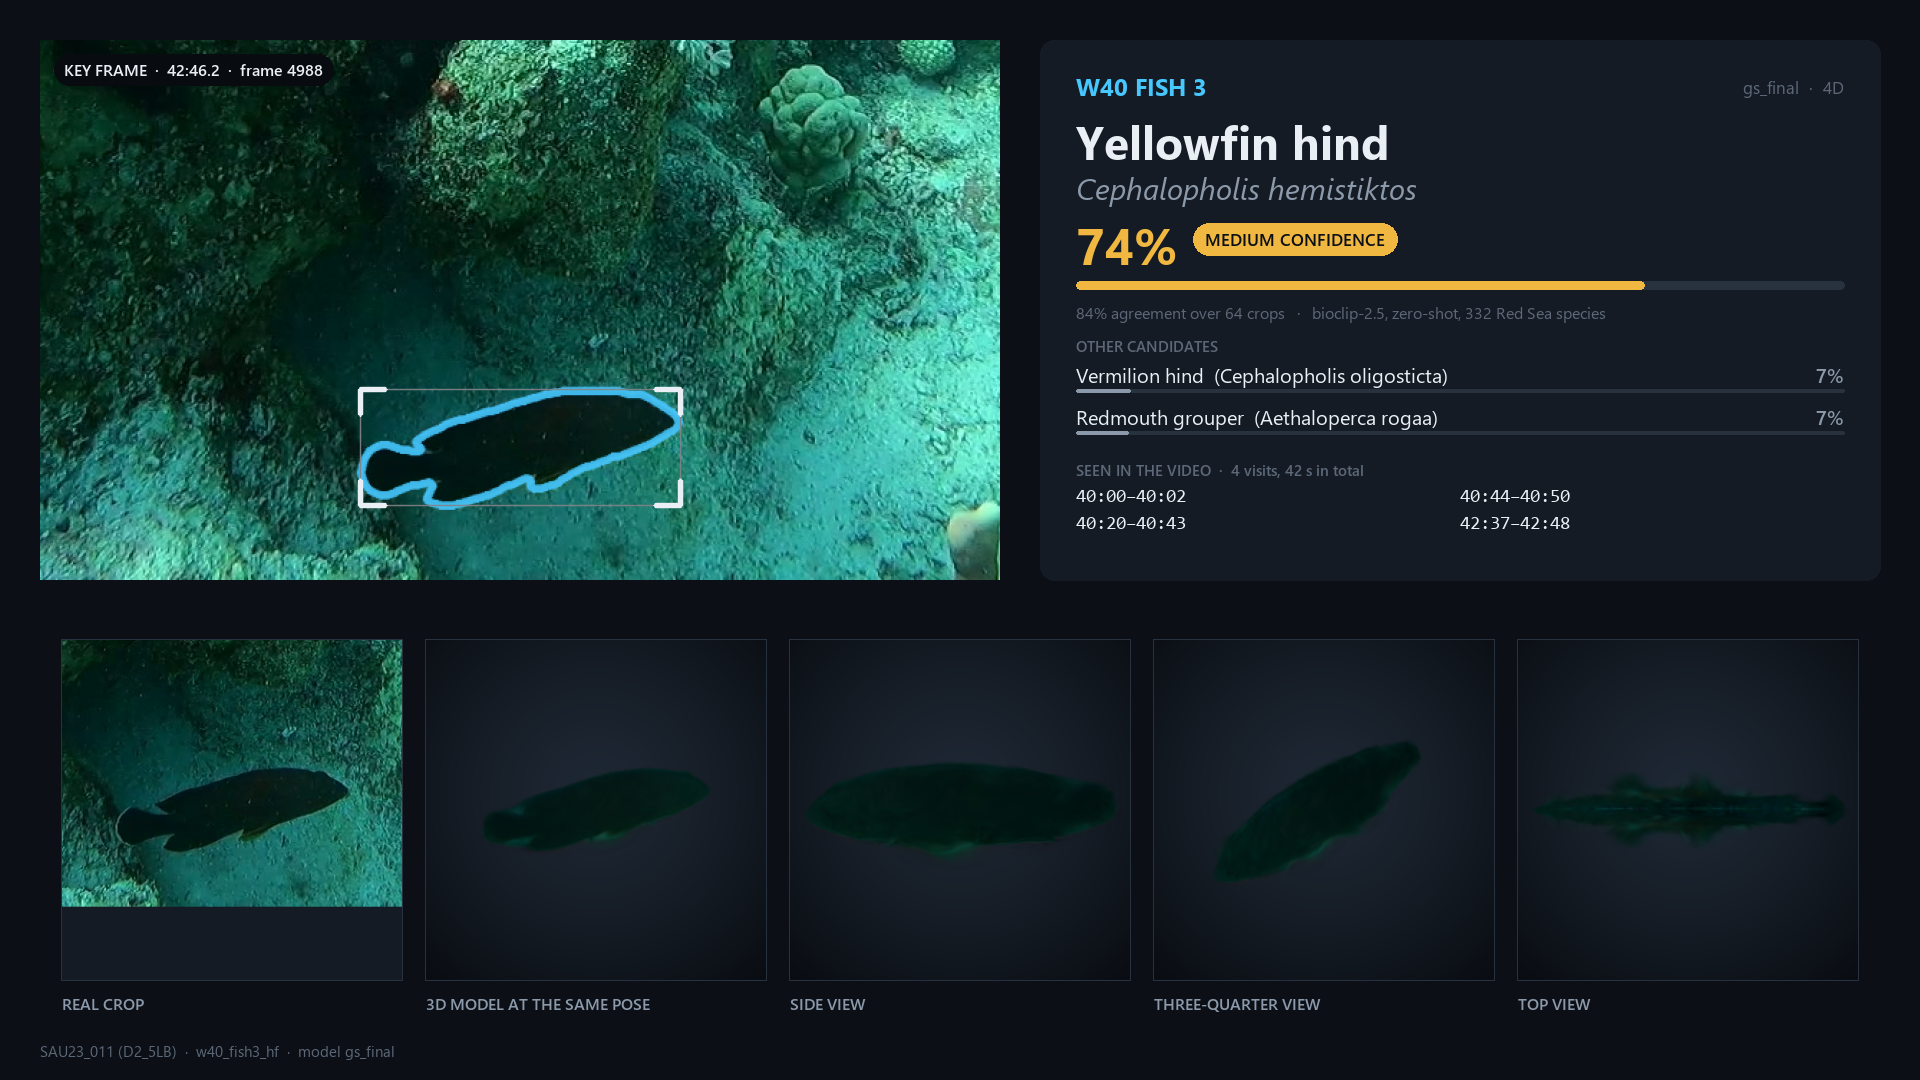
Species
Yellowfin hind Cephalopholis hemistiktos Serranidae
74.1%
Vermilion hind Cephalopholis oligosticta Serranidae
7.2%
Redmouth grouper Aethaloperca rogaa Serranidae
6.9%
Peacock hind Cephalopholis argus Serranidae
3.6%
Viridescent parrotfish Calotomus viridescens Scaridae
1.5%
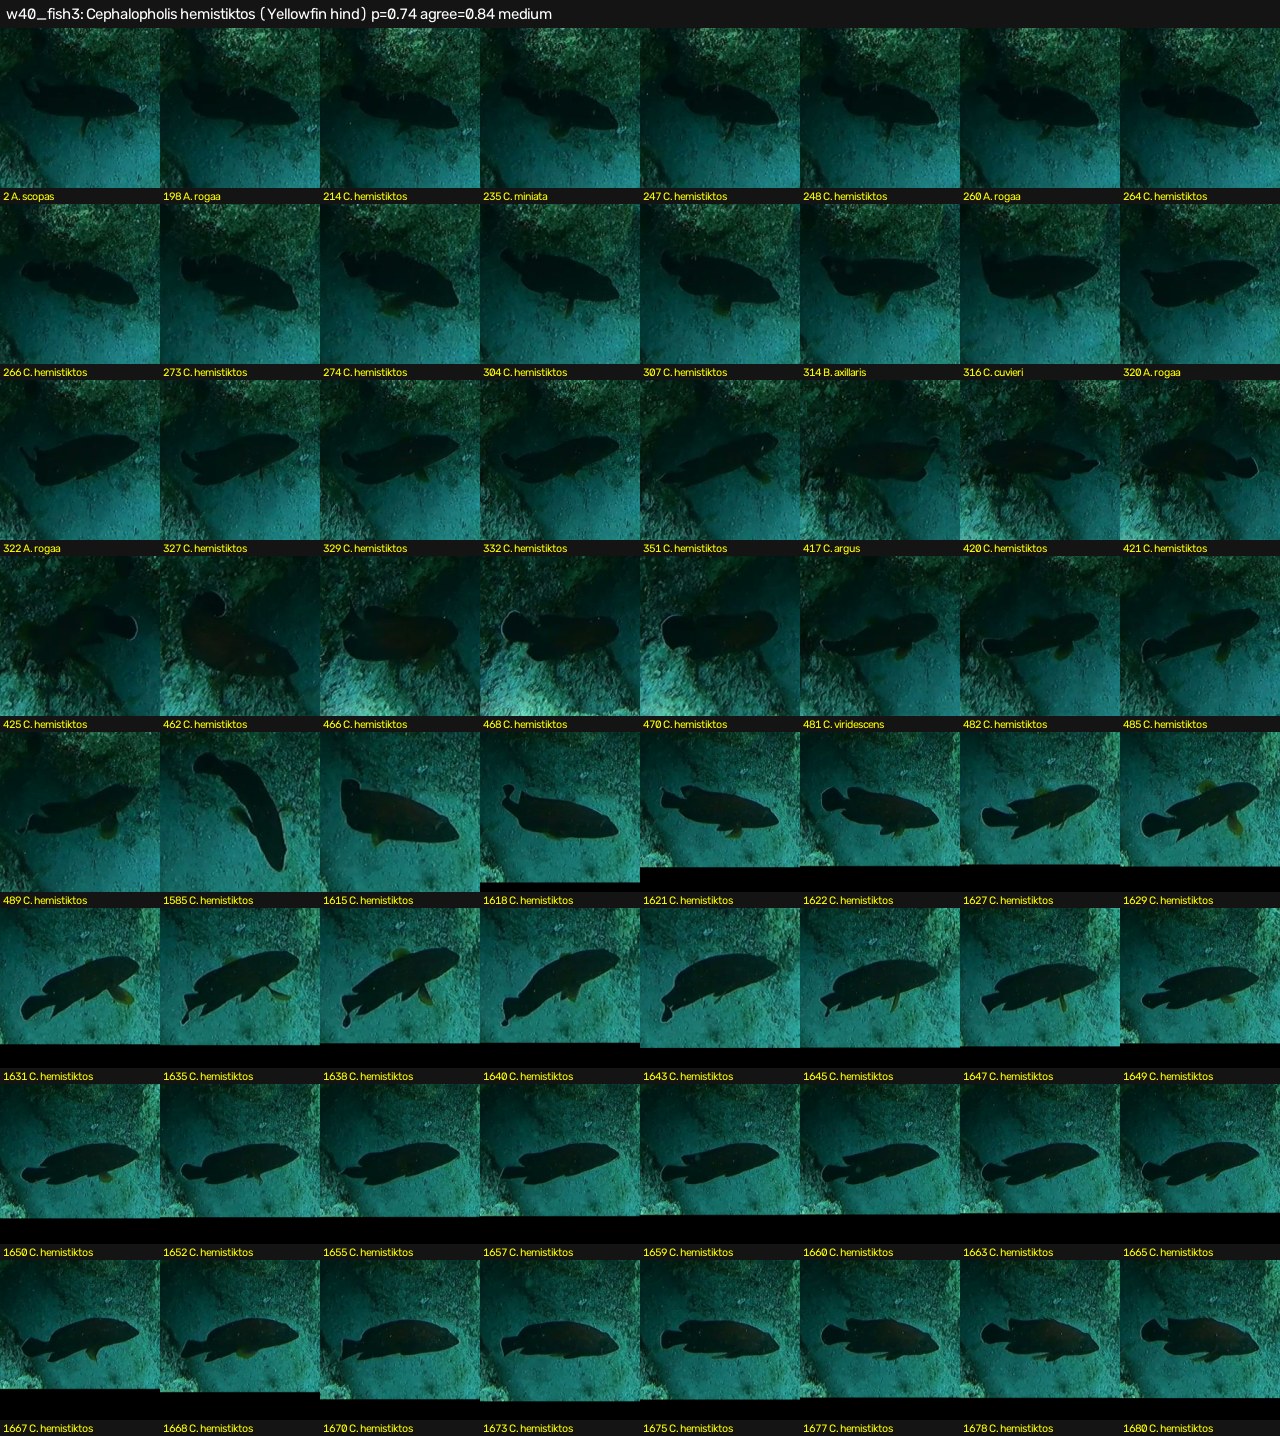
Family: Serranidae 94%, Labridae 3%, Scaridae 2% · agreement across crops 84% · 64 crops · bioclip-2.5 (hf-hub:imageomics/bioclip-2.5-vith14, open_clip, zero-shot)
Data and reconstruction
| window | 40:00 – 48:00 |
| visits | 4: 40:00-40:02, 40:20-40:42, 40:44-40:50, 42:37-42:48 |
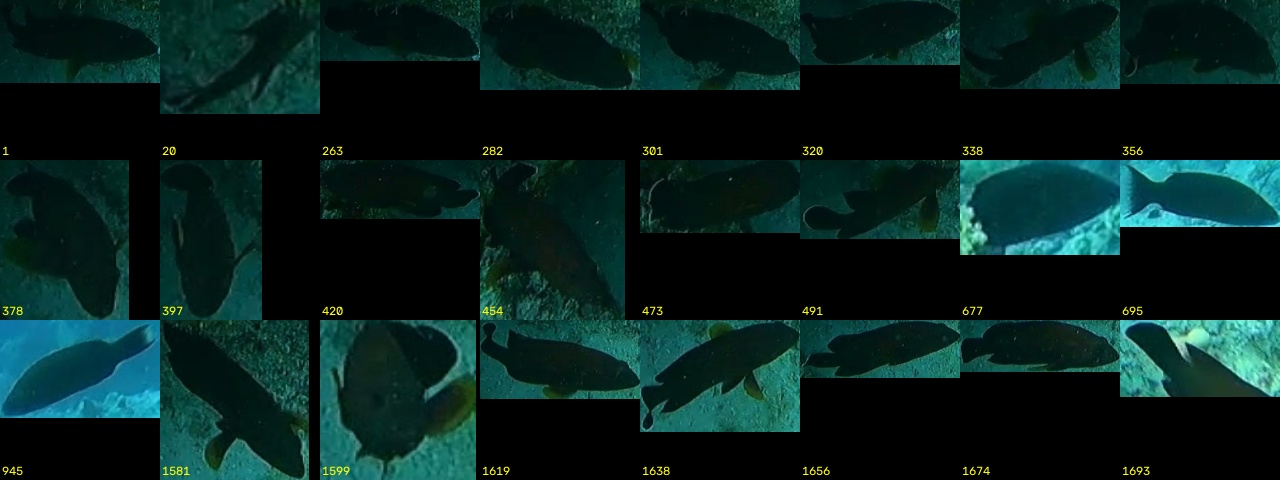
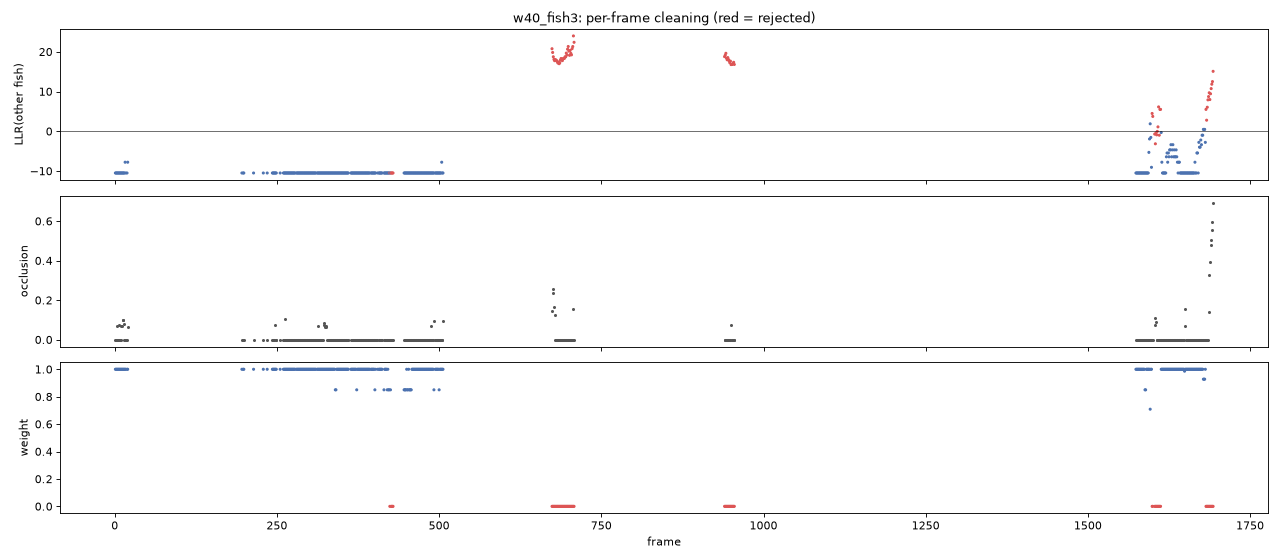
| frames (10 fps) detected / kept | 421 / 341 |
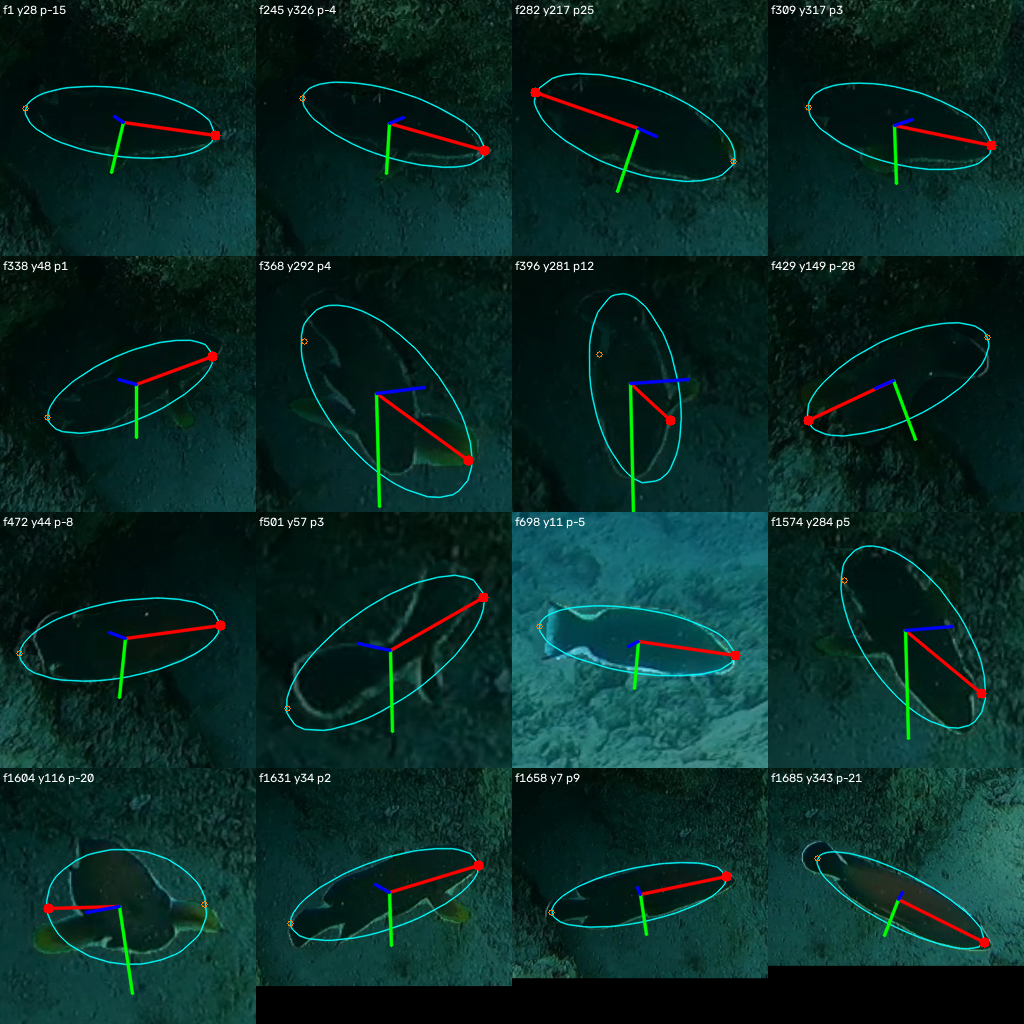
| valid poses (10 fps) | 408 |
| frames with background plate | 406 |
| median size | 160.0 px |
| 30 fps frames / valid poses | 722 / 654 |
| method | 4D GS, fins + bending + tail (30 fps) |
| model shown | v1 (gs_final) |
| iterations | 4000 |
| gaussians | 14709 |
| training time | 23 min |
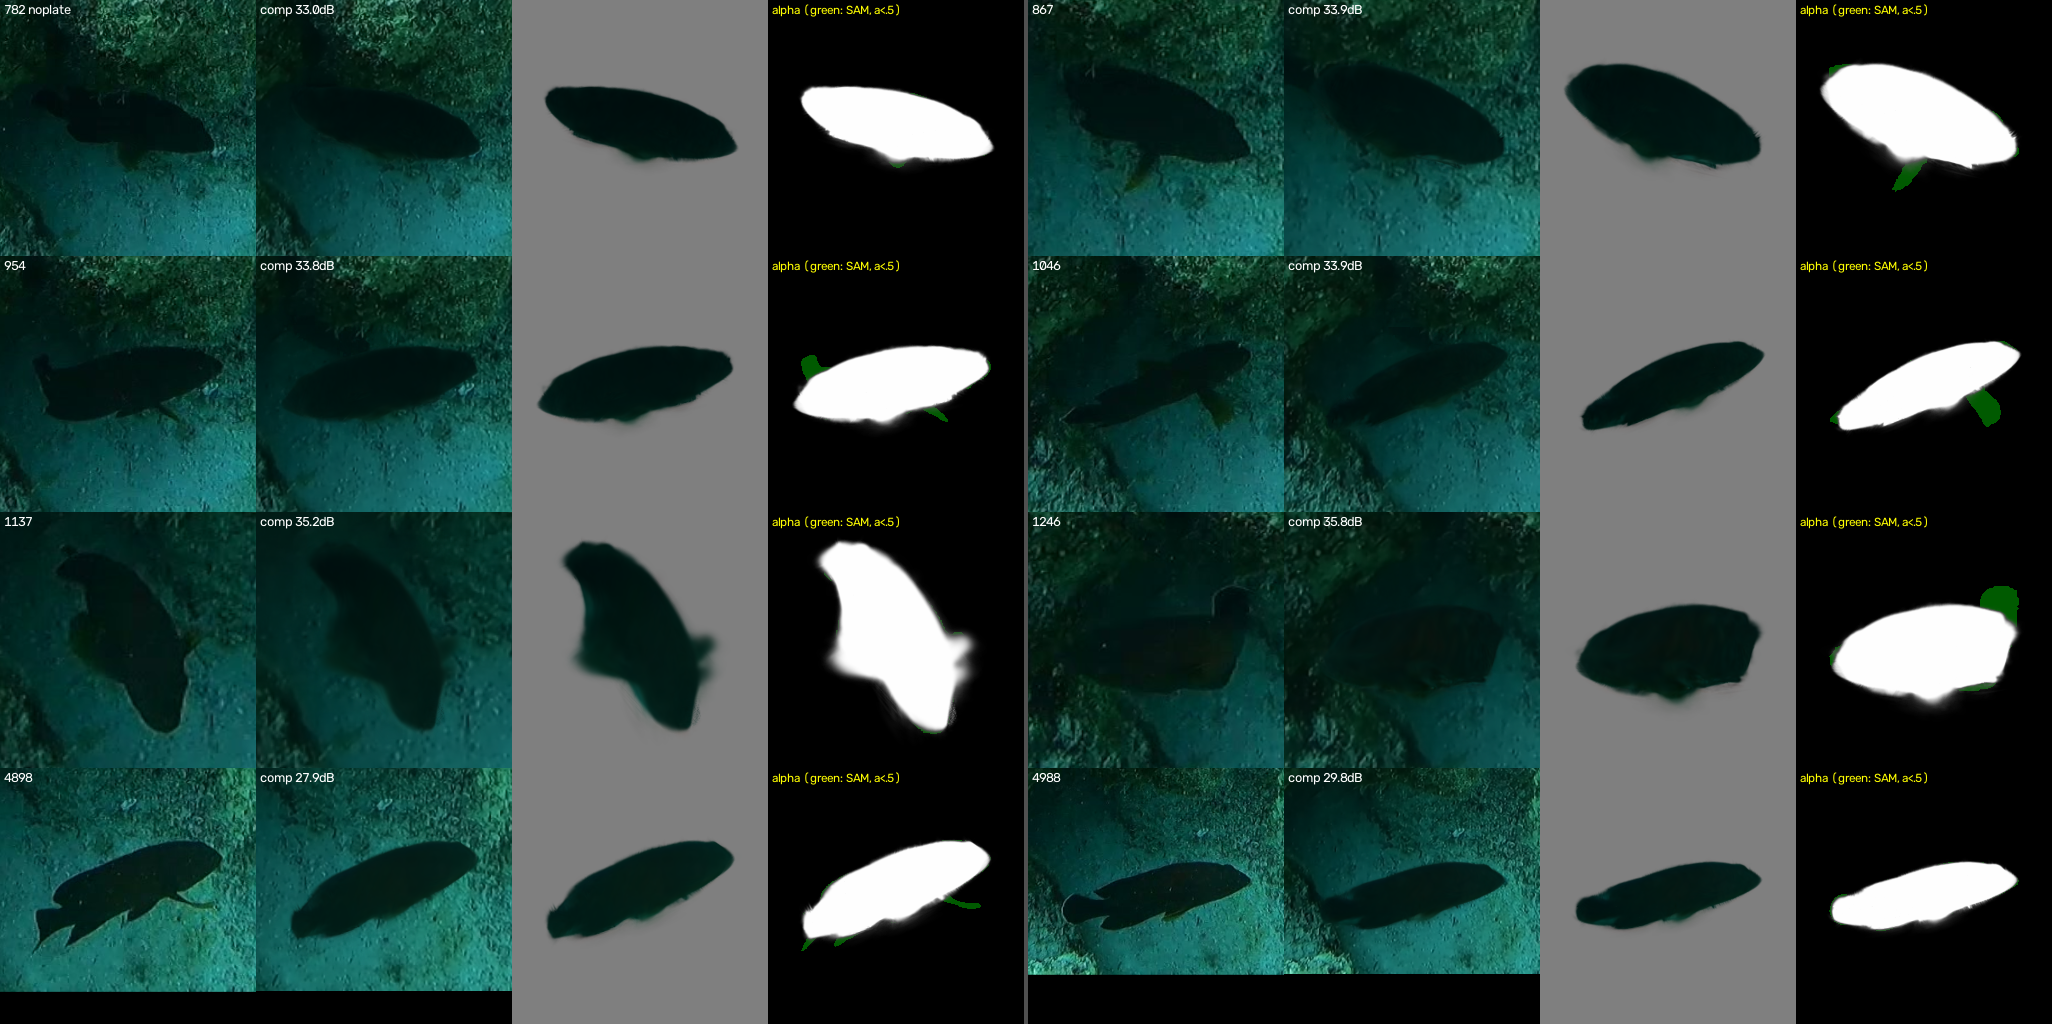
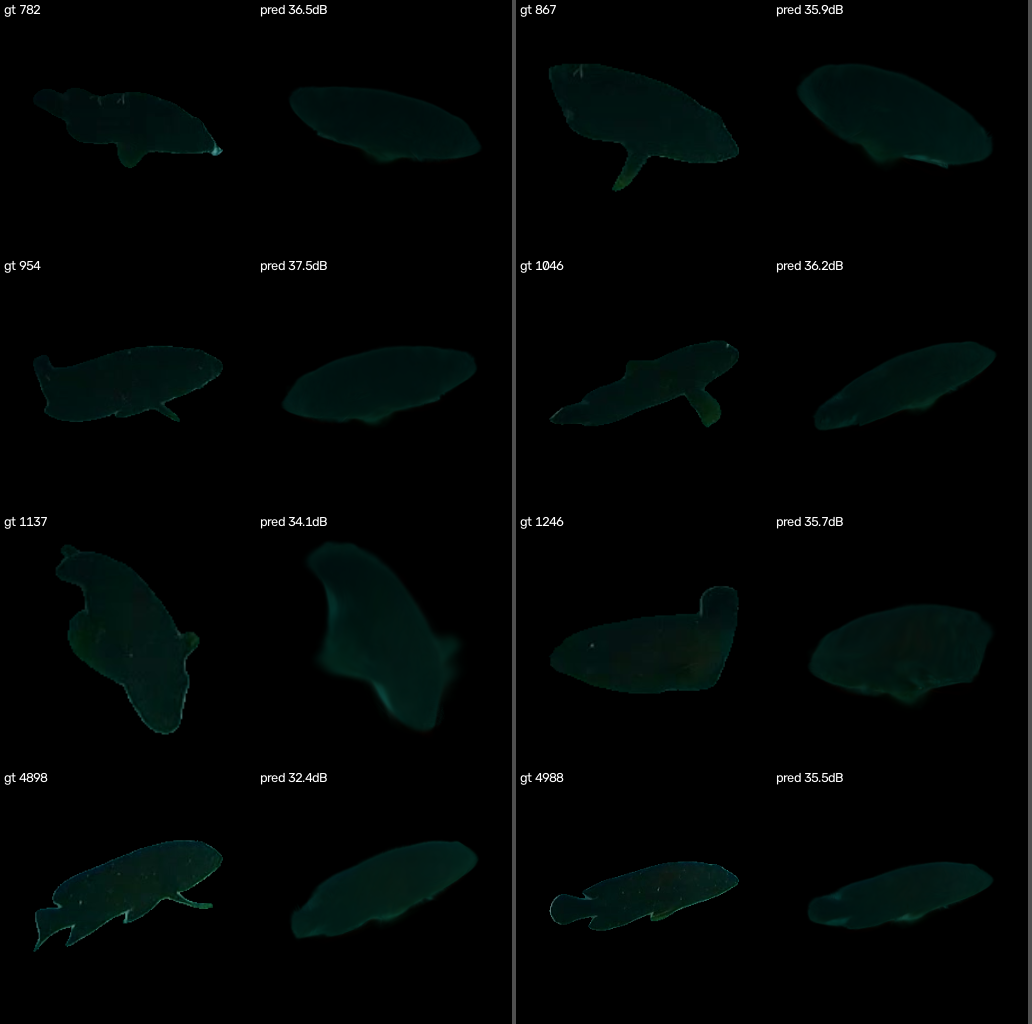
| trainer validation PSNR full / masked | 32.4 / 30.5 dB |
| trainer validation IoU vs SAM mask | 0.842 |
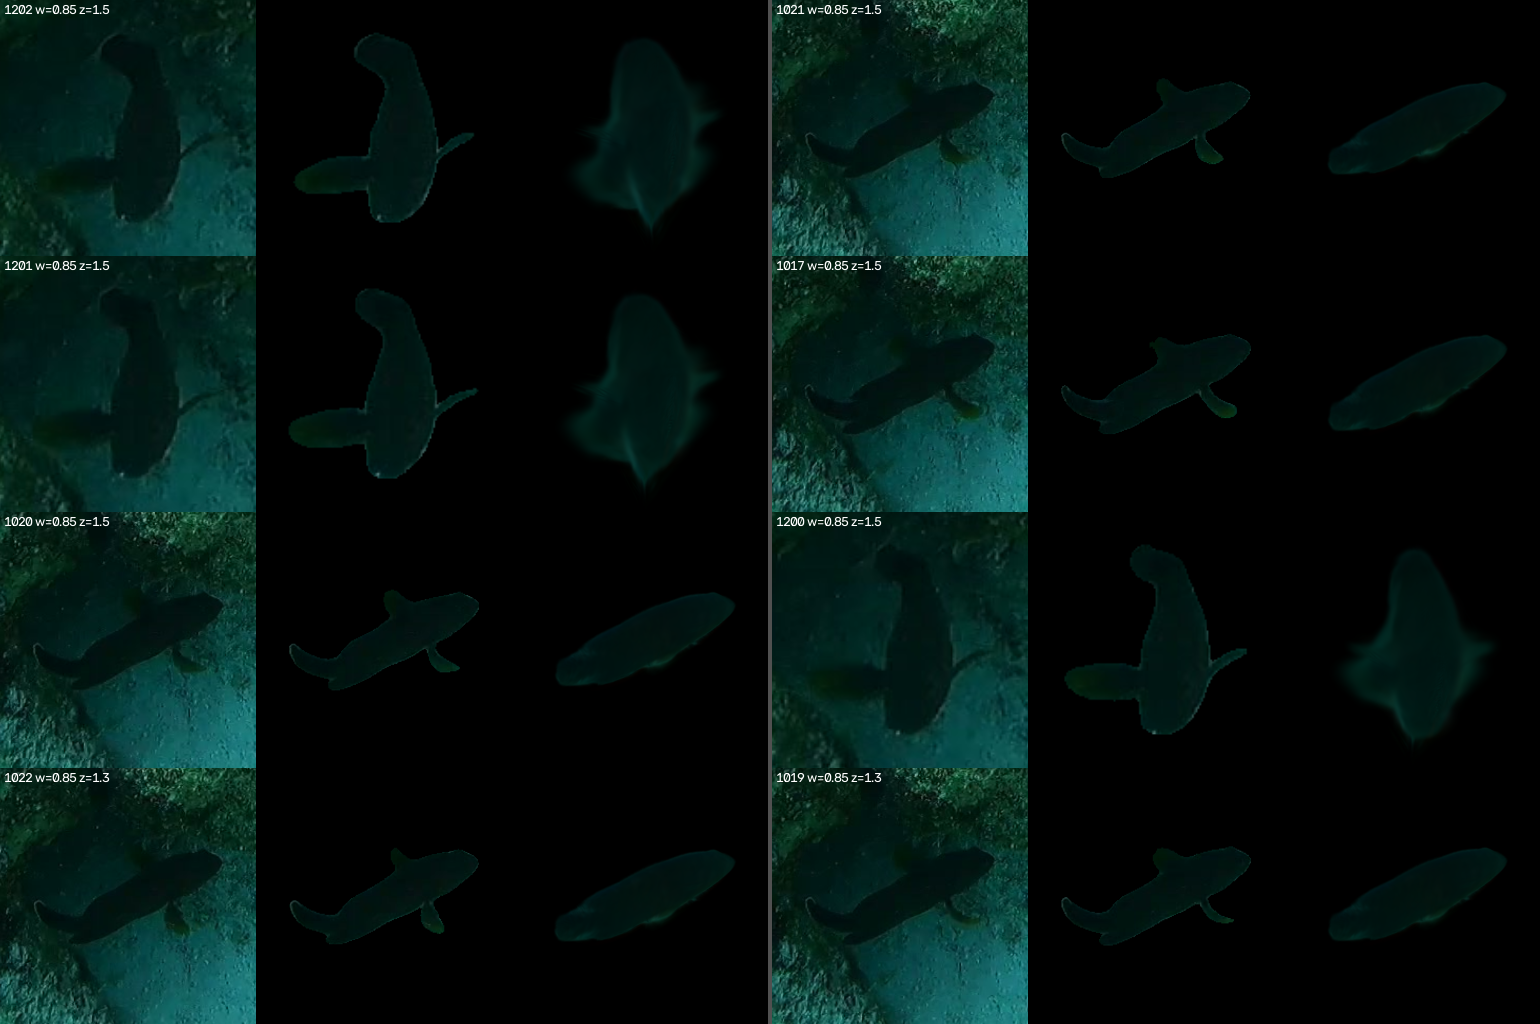
| near-fish band PSNR (fins) | 32.6 dB |
| production status | done |
| visual note (curation) | brown grouper in shadow (+ a few mid-water frames) |
Diagnostics
Downloads
point_cloud.ply (canonical 3D gaussians) · poses_refined.json · model.pt (incl. per-frame 4D params) · species.json